ROS packages for simulating a vehicle with Ackermann steering in Gazebo Classic. The repository is maintained at https://github.com/hdh7485/ackermann_vehicle and keeps the original Wunderkammer Laboratory attribution in the package metadata and source files.
| Platform | Status | Verification |
|---|---|---|
| ROS Noetic / Ubuntu 20.04 / Gazebo Classic 11 | Supported | Build and headless launch smoke test in CI and scripts/noetic_smoke_test.sh |
| ROS Melodic / Ubuntu 18.04 / Gazebo Classic 9 | Legacy | Configuration is retained, but this release does not run a Melodic CI job |
| ROS 2 Jazzy / Ubuntu 24.04 | Core support | This jazzy branch builds and passes a headless command/description smoke test |
The original full-simulation release is ROS Noetic. The sensor variants require
the matching Gazebo sensor plugins; the default headless smoke test
intentionally exercises the base vehicle and controller path. The validated
controller path uses the root namespace (namespace:=/); custom namespaces are
not covered by that release's smoke test.
This is the distribution-specific jazzy branch. The ROS 2 package,
ackermann_vehicle_ros2, provides a maintained
geometry_msgs/Twist to ackermann_msgs/AckermannDriveStamped bridge and an
installed E-Maxx xacro for robot_state_publisher. It is built and
smoke-tested only against ROS 2 Jazzy in this branch. Build it from a fresh
Jazzy workspace:
mkdir -p ~/ros2_ws/src
cd ~/ros2_ws/src
git clone --branch jazzy https://github.com/hdh7485/ackermann_vehicle.git
cd ~/ros2_ws
source /opt/ros/jazzy/setup.bash
colcon build --packages-select ackermann_vehicle_ros2
source install/setup.bash
Run the bridge or the reproducible headless check:
ros2 launch ackermann_vehicle_ros2 cmd_vel_to_ackermann_drive.launch.py
ros2 topic pub --once /cmd_vel geometry_msgs/msg/Twist \
  '{linear: {x: 2.0}, angular: {z: 1.0}}'

ROS2_WS=$PWD bash src/ackermann_vehicle/scripts/ros2_smoke_test.sh
The smoke script defaults to ROS domain 203 so it does not attach to an
interactive graph; set ACKERMANN_ROS_DOMAIN_ID to override it. It rejects a
non-Jazzy environment so the branch cannot silently be tested against another
ROS distribution. ROS 2 Gazebo
world, sensor, and ros2_control controller adapters are not yet shipped:
Foxy/Humble need a Gazebo Classic adapter, while Jazzy needs a modern Gazebo
(ros_gz/Harmonic) adapter. See docs/ROS2_GAZEBO_PLAN.md
for those explicitly separate migration milestones.
mkdir -p ~/catkin_ws/src
cd ~/catkin_ws/src
git clone --branch noetic https://github.com/hdh7485/ackermann_vehicle.git
cd ~/catkin_ws
rosdep update
rosdep install --from-paths src --ignore-src -r -y
catkin_make
source devel/setup.bash
For a repeatable, display-free check from the workspace, run:
bash src/ackermann_vehicle/scripts/noetic_smoke_test.shThe script starts a temporary ROS master, launches
ackermann_vehicle_gazebo/launch/ackermann_vehicle_noetic.launch with Gazebo
GUI disabled, and verifies that the Ackermann node and controller-manager
services are available. To run it manually with a visible simulator:
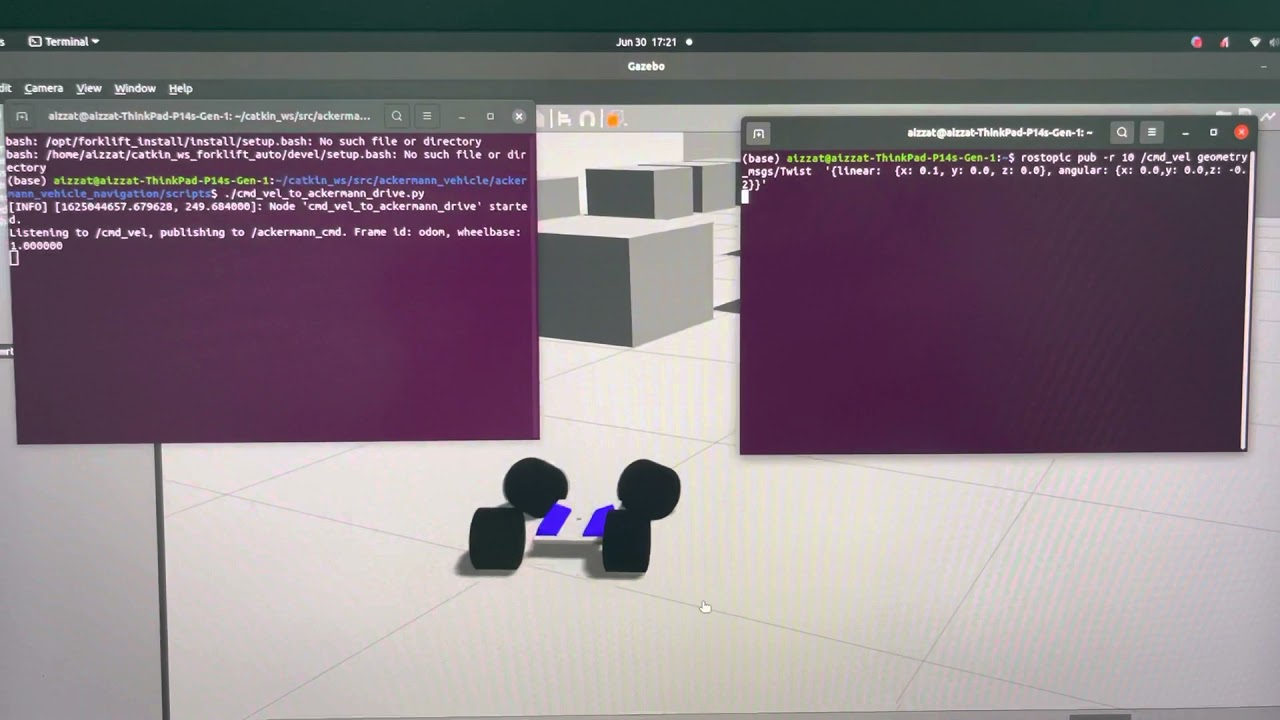
roslaunch ackermann_vehicle_gazebo ackermann_vehicle_noetic.launchThe controller consumes ackermann_msgs/AckermannDrive on /ackermann_cmd.
The navigation package also provides a cmd_vel converter:
rosrun ackermann_vehicle_navigation cmd_vel_to_ackermann_drive.py
rostopic pub -r 10 /cmd_vel geometry_msgs/Twist \
'{linear: {x: 0.1, y: 0.0, z: 0.0}, angular: {x: 0.0, y: 0.0, z: 0.2}}'The Noetic launch files now load the controller YAML before invoking the
Noetic controller_manager/spawner, pass an explicit service timeout, and
expose gui, paused, and use_sim_time arguments. This addresses the
controller-spawner race/failure mode reported in issue #3 and makes the
headless path used by issue #4 reproducible. The joy launch file now points
to the converter in ackermann_vehicle_navigation, where catkin installs it.
If a local Gazebo installation still fails to load the model, capture the
smoke-test log from /tmp/ackermann_vehicle_ros_smoke and include the ROS,
Gazebo, and controller versions in the issue report. Hardware-specific Hokuyo
topics are outside the base controller smoke test.
This package was updated from earlier open-source Ackermann vehicle work. See the Apache-2.0 license and the per-package changelogs for attribution and maintenance history.